About

Hi, I am Ruining Yang (pronounce: ray-ning-young), a third year PhD in Computer Engineering at TRUST AI Lab, Northeastern University. I am fortunate to be advised by Prof. Lili Su. My research focuses on efficient learning from informative samples for End-to-End, Vision-Language-Action (VLA), and World Action Model (WAM) approaches in autonomous driving, with an emphasis on robust decision-making in complex real-world scenarios.
Education

  • PhD in Computer Engineering, Northeastern University 09/2024 – Present · Boston, MA
  • MS in Computer Science, Northeastern University 01/2022 – 08/2024 · Boston, MA
  • BA in Communications, University of Colorado Denver 03/2018 – 07/2021 · Denver, CO

Experience | More Details >

  • Research Intern, Bosch Center for Artificial Intelligence (BCAI) 05/2026 – Present · Sunnyvale, CA
  • Research Intern, Motional 09/2025 – 05/2026 · Boston, MA
  • Research Assistant, Australian National University 05/2023 – 12/2023 · Canberra, Australia

📝 Selected Publications | See All Publications > | * Equal contribution   † Corresponding author

paper teaser

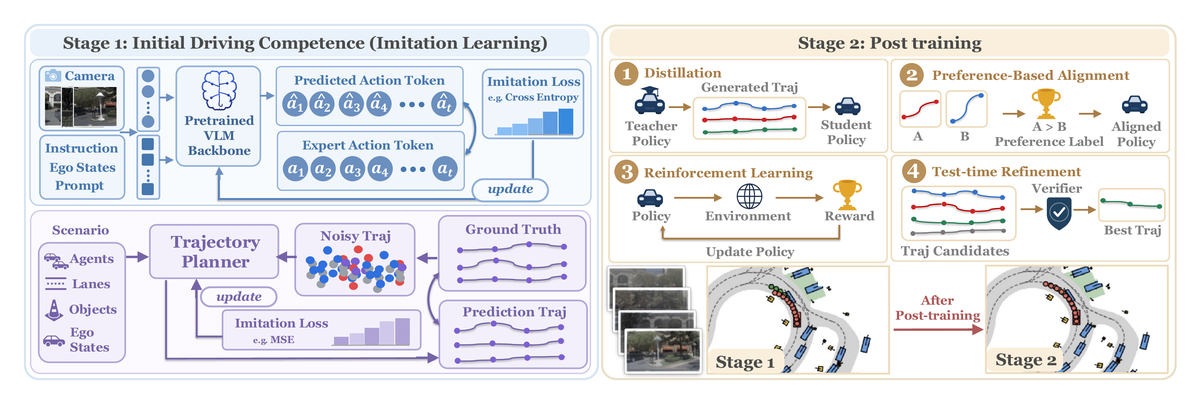
Post-Training in End-to-End Autonomous Driving: A Unified View

Ruining Yang*, Muxing Wang*, Yixiao Chen, Tongfei Guo, Yi Xu, Can Cui, Zichong Yang, Yitian Zhang, Ziran Wang, Yun Fu, Lili Su

🏆 Best Paper Award, ECCV 2026 DriveX Workshop

paper teaser

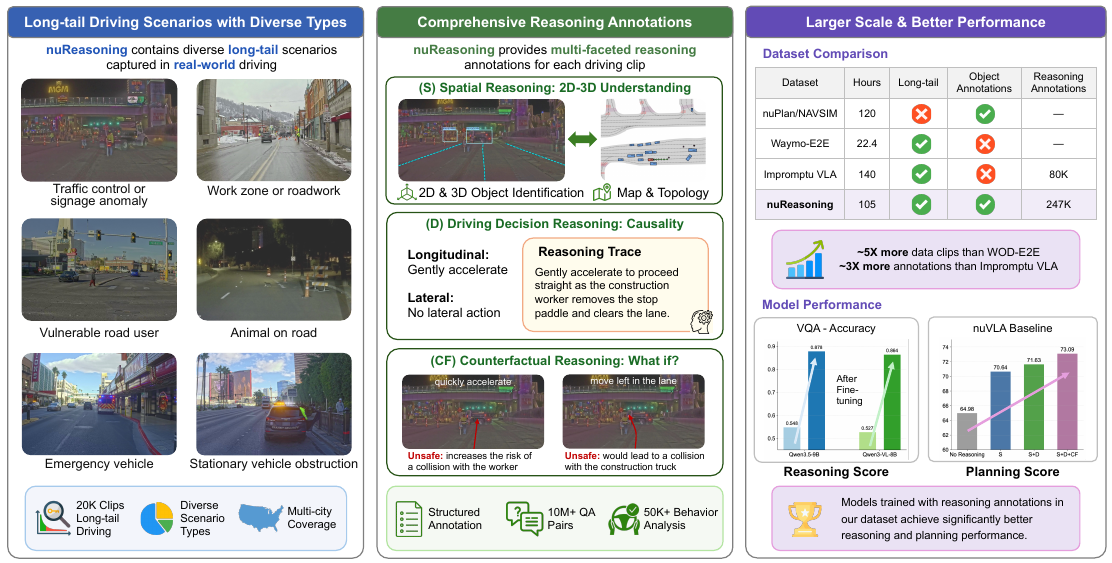
nuReasoning: A Reasoning-Centric Dataset and Benchmark for Long-Tail Autonomous Driving

Zhiyu Huang*, Johnson Liu*, Rui Song*, Zewei Zhou, Ruining Yang, Yun Zhang, Tianhui Cai, Hanyin Zhang, Mingxuan Gao, Valeria Xu, Jiali Chen, Yishan Shen, Yiluan Guo, Tony (Xuewei) Qi†, Jiaqi Ma

Official nu-Dataset Series of Motional (nuScenes, nuPlan, nuReasoning)

paper teaser

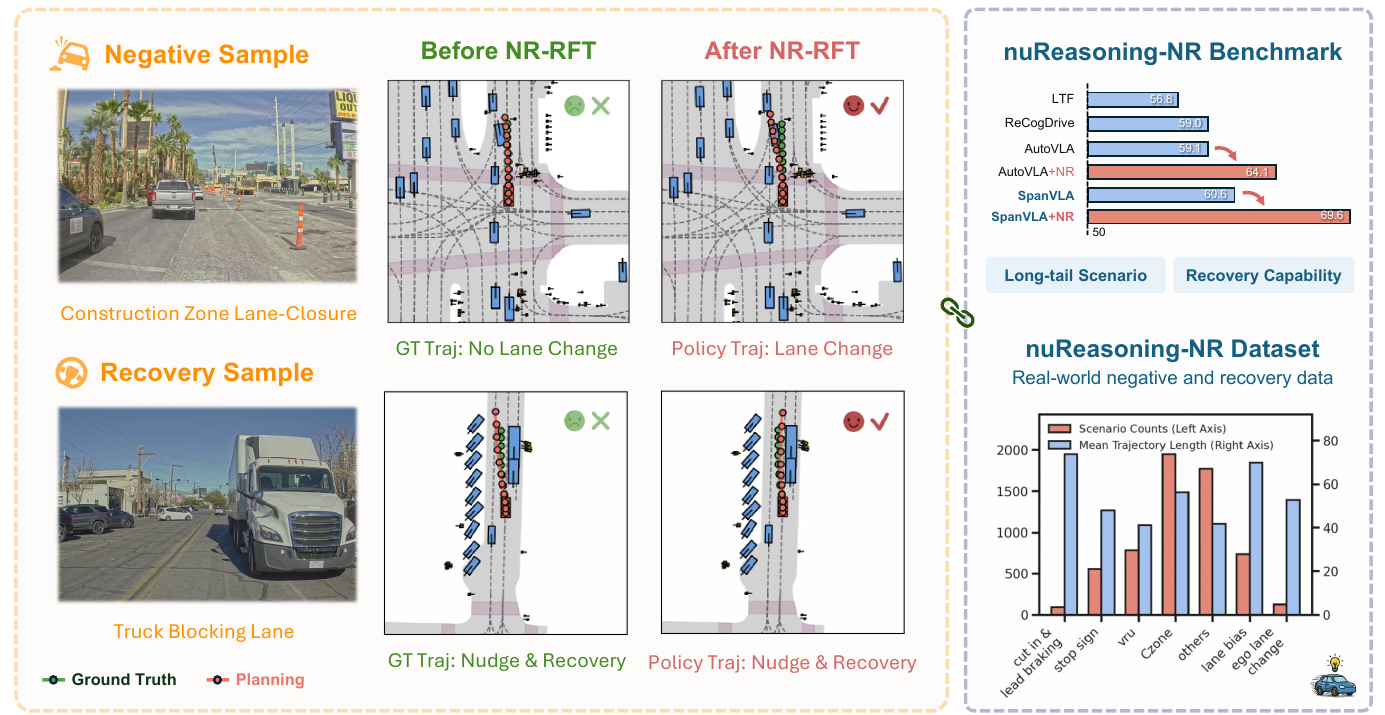
SpanVLA: Learning from Negative-Recovery Samples with Fast Action Bridging for Vision-Language-Action Model

Zewei Zhou*, Ruining Yang*, Xuewei (Tony) Qi†, Yiluan Guo, Sherry X. Chen, Tao Feng, Kateryna Pistunova, Yishan Shen, Lili Su, Jiaqi Ma

🏆 Best Innovation Paper Award, ECCV 2026 DriveX Workshop

paper teaser

Den-TP: A Density-Balanced Data Curation and Evaluation Framework for Trajectory Prediction

Ruining Yang, Yi Xu, Yun Fu, Lili Su